Factory Inspection
Support routine observation around production equipment, facility corridors and designated inspection areas. Reduce the need for repeated manual visits where remote observation is suitable.
QADIR Industrial Robotics
Compact Mobility. Industrial Possibilities.
A compact quadruped robotic platform designed for industrial inspection, security applications and customized system integration.
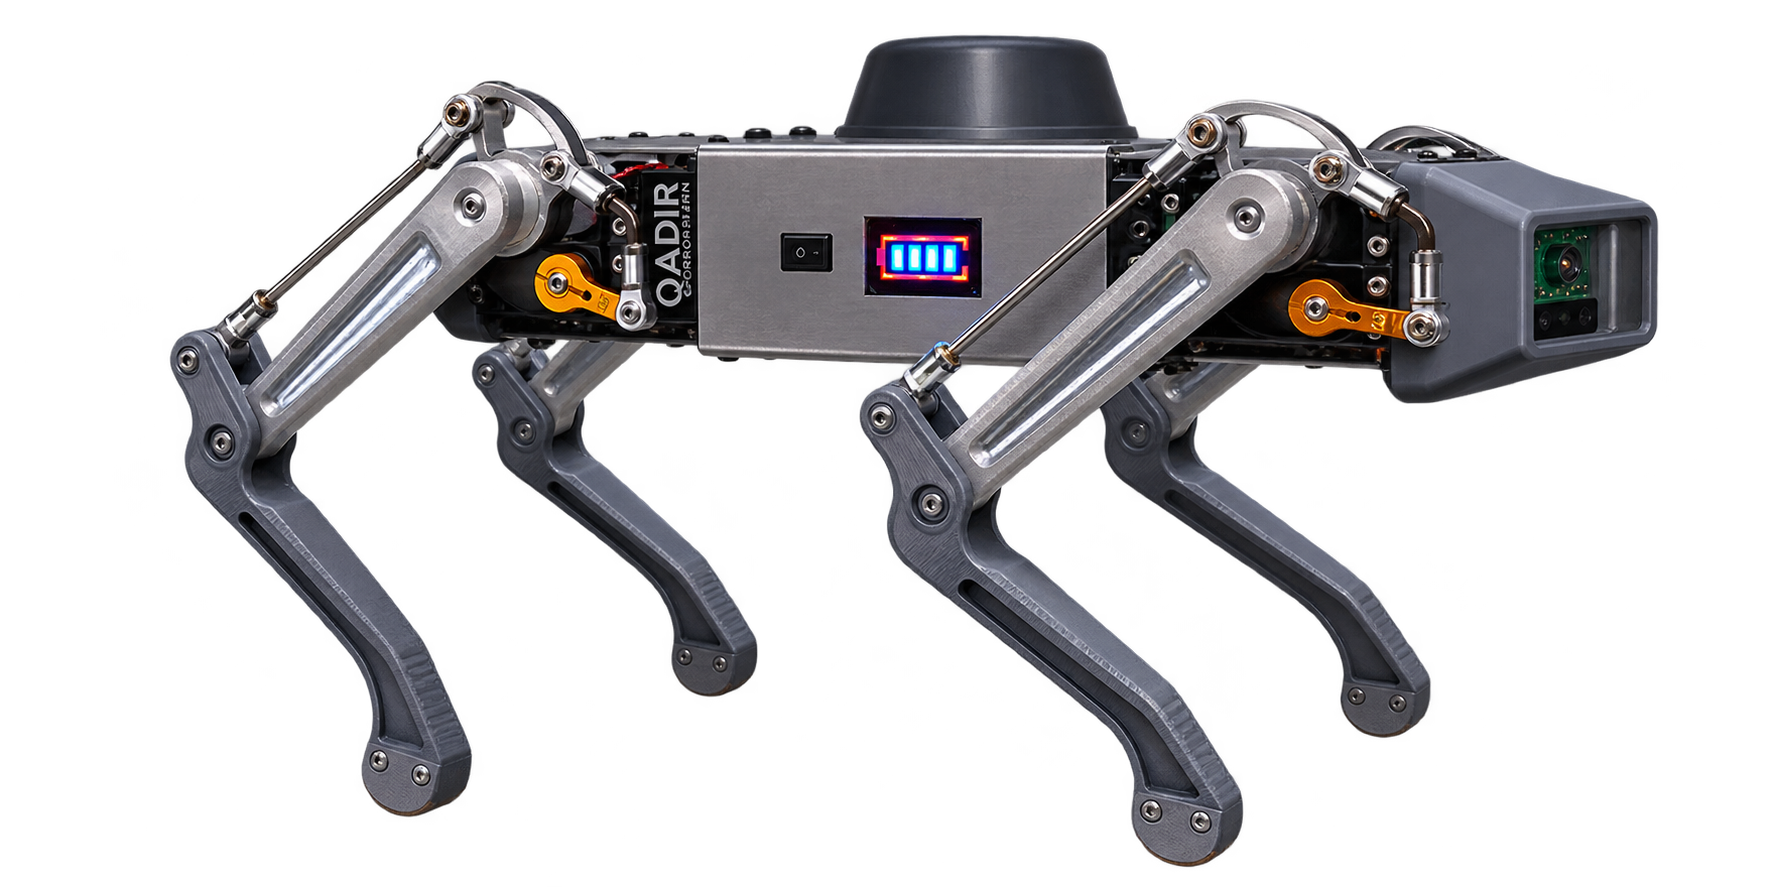
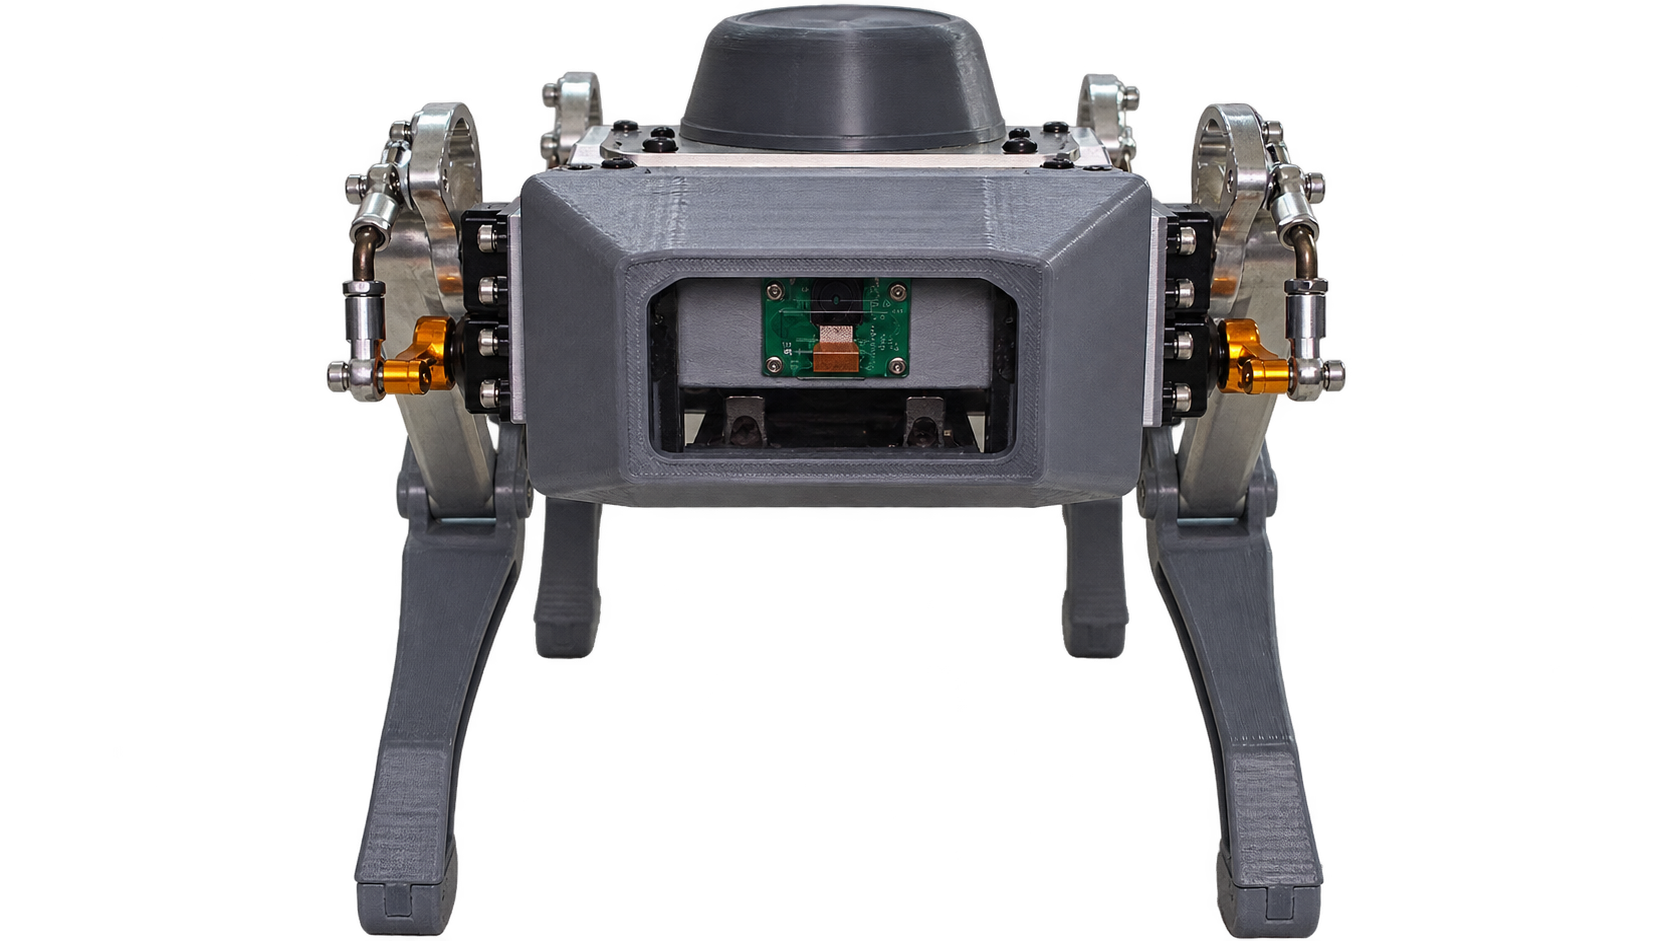
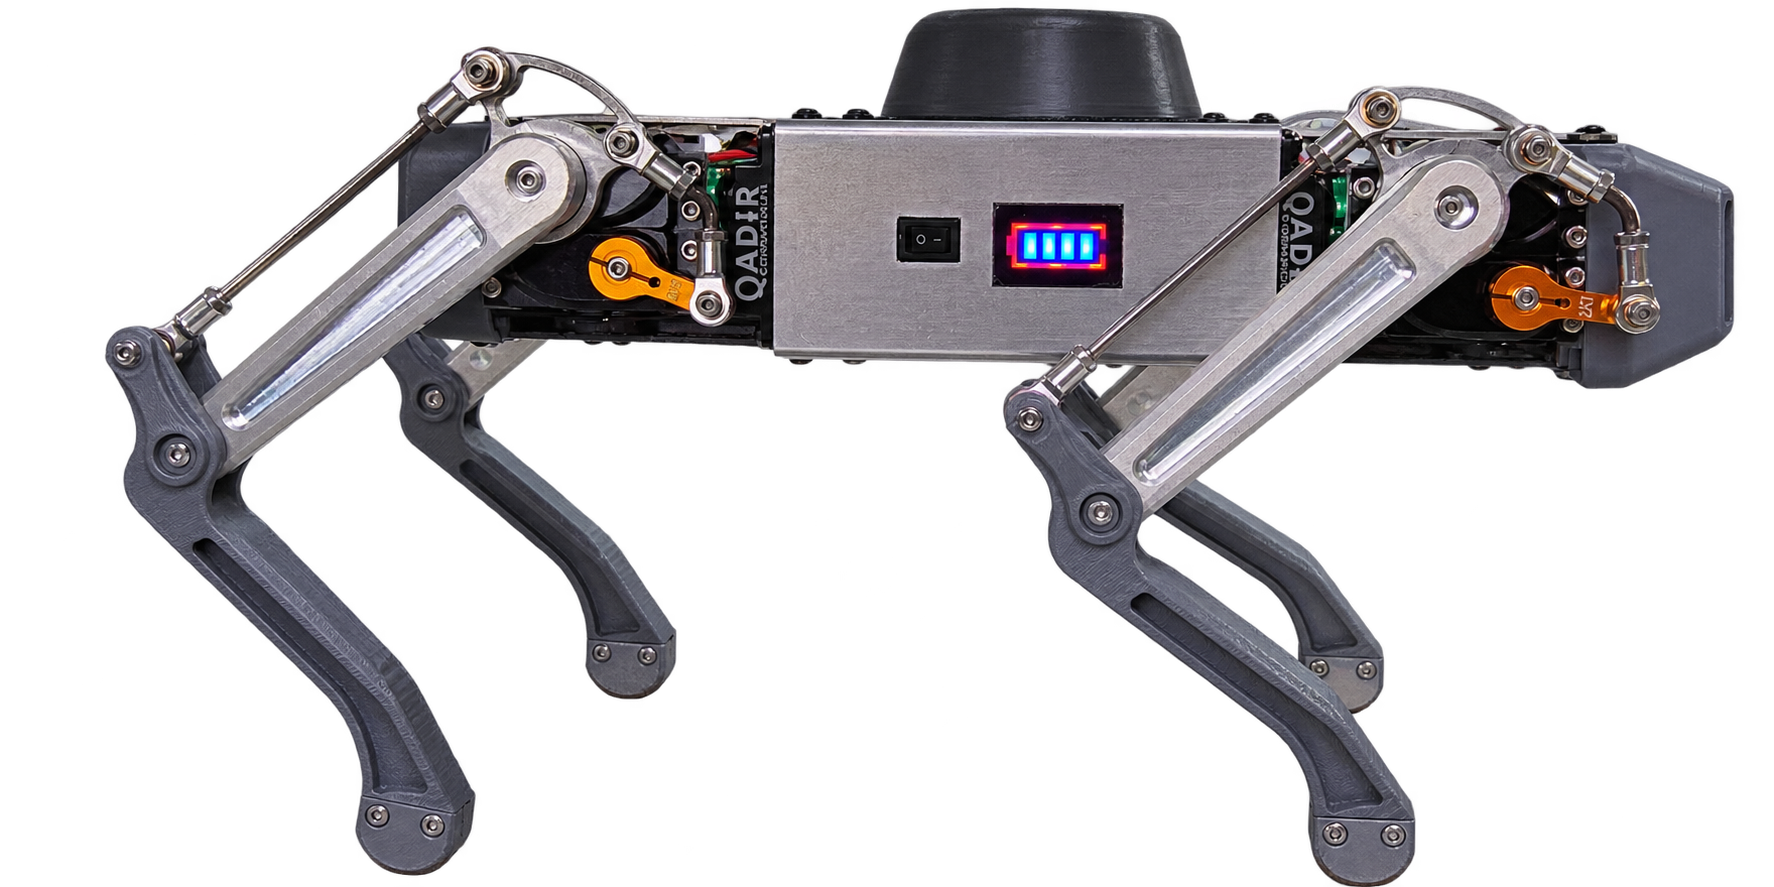
Built for Real-World Operations
P105 V6 brings compact robotic mobility to industrial environments where routine inspection, remote observation and access flexibility matter. Each deployment is evaluated according to site conditions and operational needs.
Support routine observation around production equipment, facility corridors and designated inspection areas. Reduce the need for repeated manual visits where remote observation is suitable.
Extend security observation into warehouse aisles and indoor operating areas. Video streaming and integration with existing security infrastructure depend on network and system configuration.
Explore inspection opportunities in narrow passages and restricted-access areas where larger robotic platforms may be impractical. Site access and operating conditions require individual assessment.
Application suitability, navigation requirements and inspection coverage are determined through project-specific evaluation.
Designed and Engineered by QADIR
From mechanical design and custom RC servos to motion simulation and system integration, QADIR develops its quadruped platforms with a focus on practical engineering and serviceability.
Designed and engineered by QADIR, with manufacturing carried out by a Taiwan-based production partner. The architecture supports practical maintenance and component replacement.
Quadruped mechanical architecture, articulated linkages and integrated body design developed for compact mobility.
Physics-based simulation supports the evaluation of robotic motion and mechanical behavior during development.
Integration of control systems, communication, optional sensing equipment and application-specific functions.
A look at QADIR's quadruped motion development through physics-based simulation. Simulation results do not represent verified field performance.
P105 V6 / Product Information
A compact quadruped robotic platform designed for industrial applications and system integration.
Test conditions: The maximum climbing angle of 37° was measured on a slope of fine loose gravel, using rubber foot pads, no additional payload, and a special half-height posture at low speed. This result reflects specific test conditions and may not be reproducible in all environments. Actual performance may vary with surface material, particle size, surface stability, traction, and payload.
*Peak payload is subject to operating limitations. Full mobility and posture transitions are not guaranteed at peak load.
Compact four-legged mobility for suitable operating environments.
Autonomous roaming behavior. Does not guarantee waypoint patrol or complete area coverage.
Video streaming is supported, subject to camera configuration and network conditions.
Additional sensing, navigation and communication functions can be evaluated according to project requirements.
Optional sensing hardware and integration.
Optional positioning and return-to-base integration.
Requires site mapping or calibration and project evaluation.
External antenna and network solutions subject to site conditions.
Specifications and available integrations may vary by configuration. Please contact QADIR for project-specific requirements.
Explore the engineering behind P105 V6, from its compact mechanical design and proprietary control architecture to terrain adaptability and customization.
PDF · V1.8